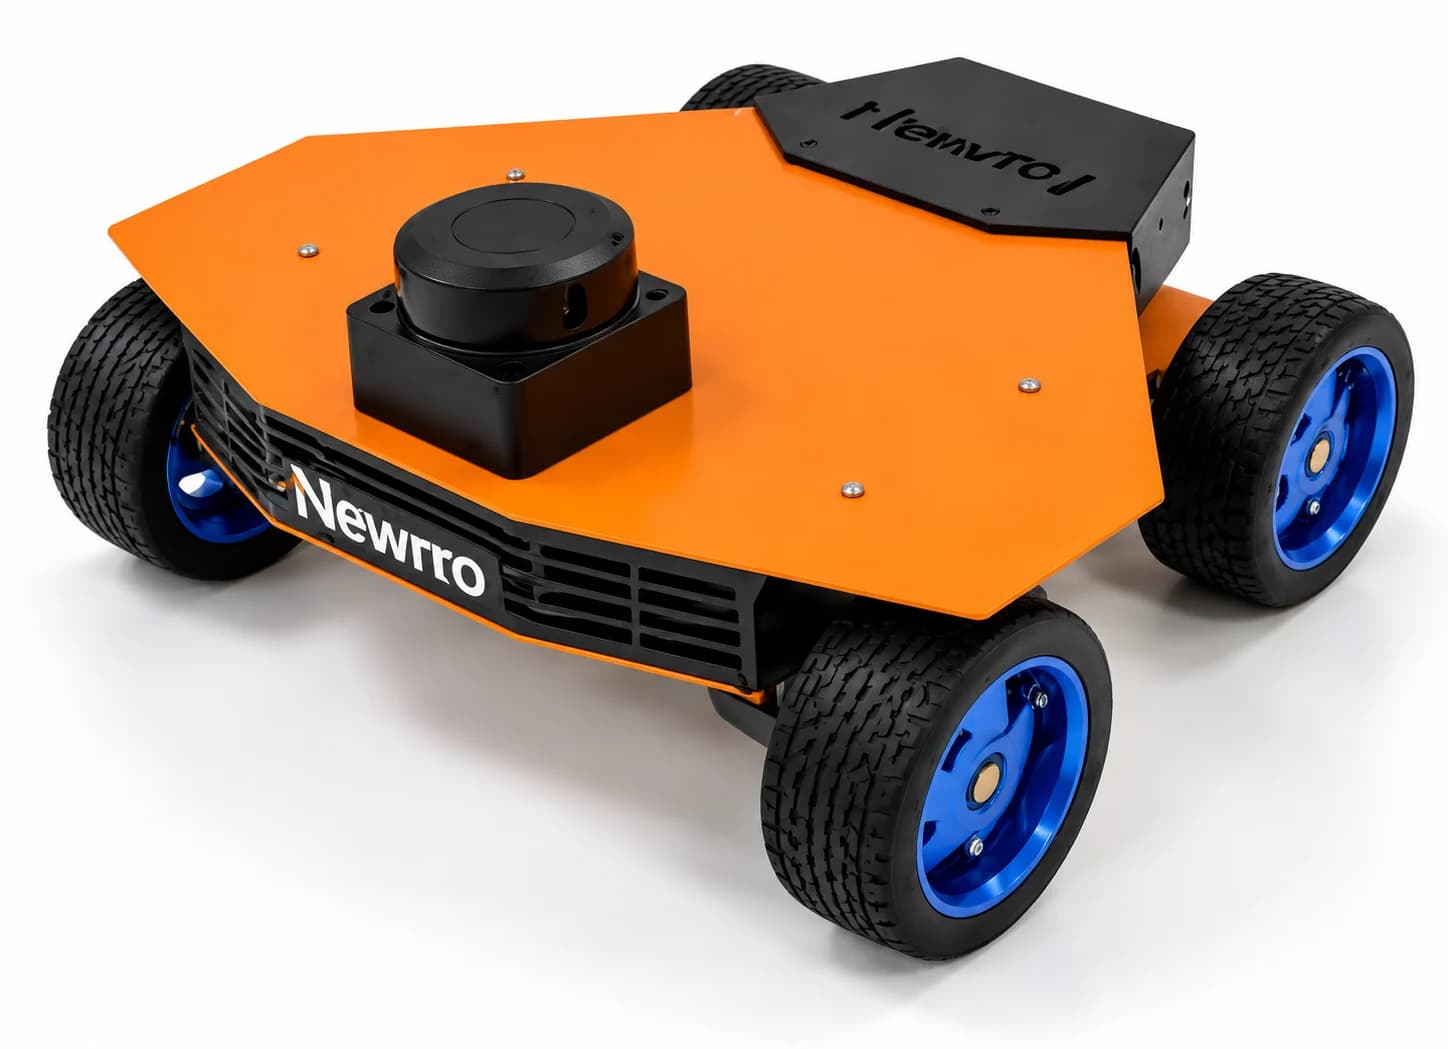
AMR
EntryBABHRU
Lightweight ROS 2 mobile robot for students, educators and researchers.
Configurations & specs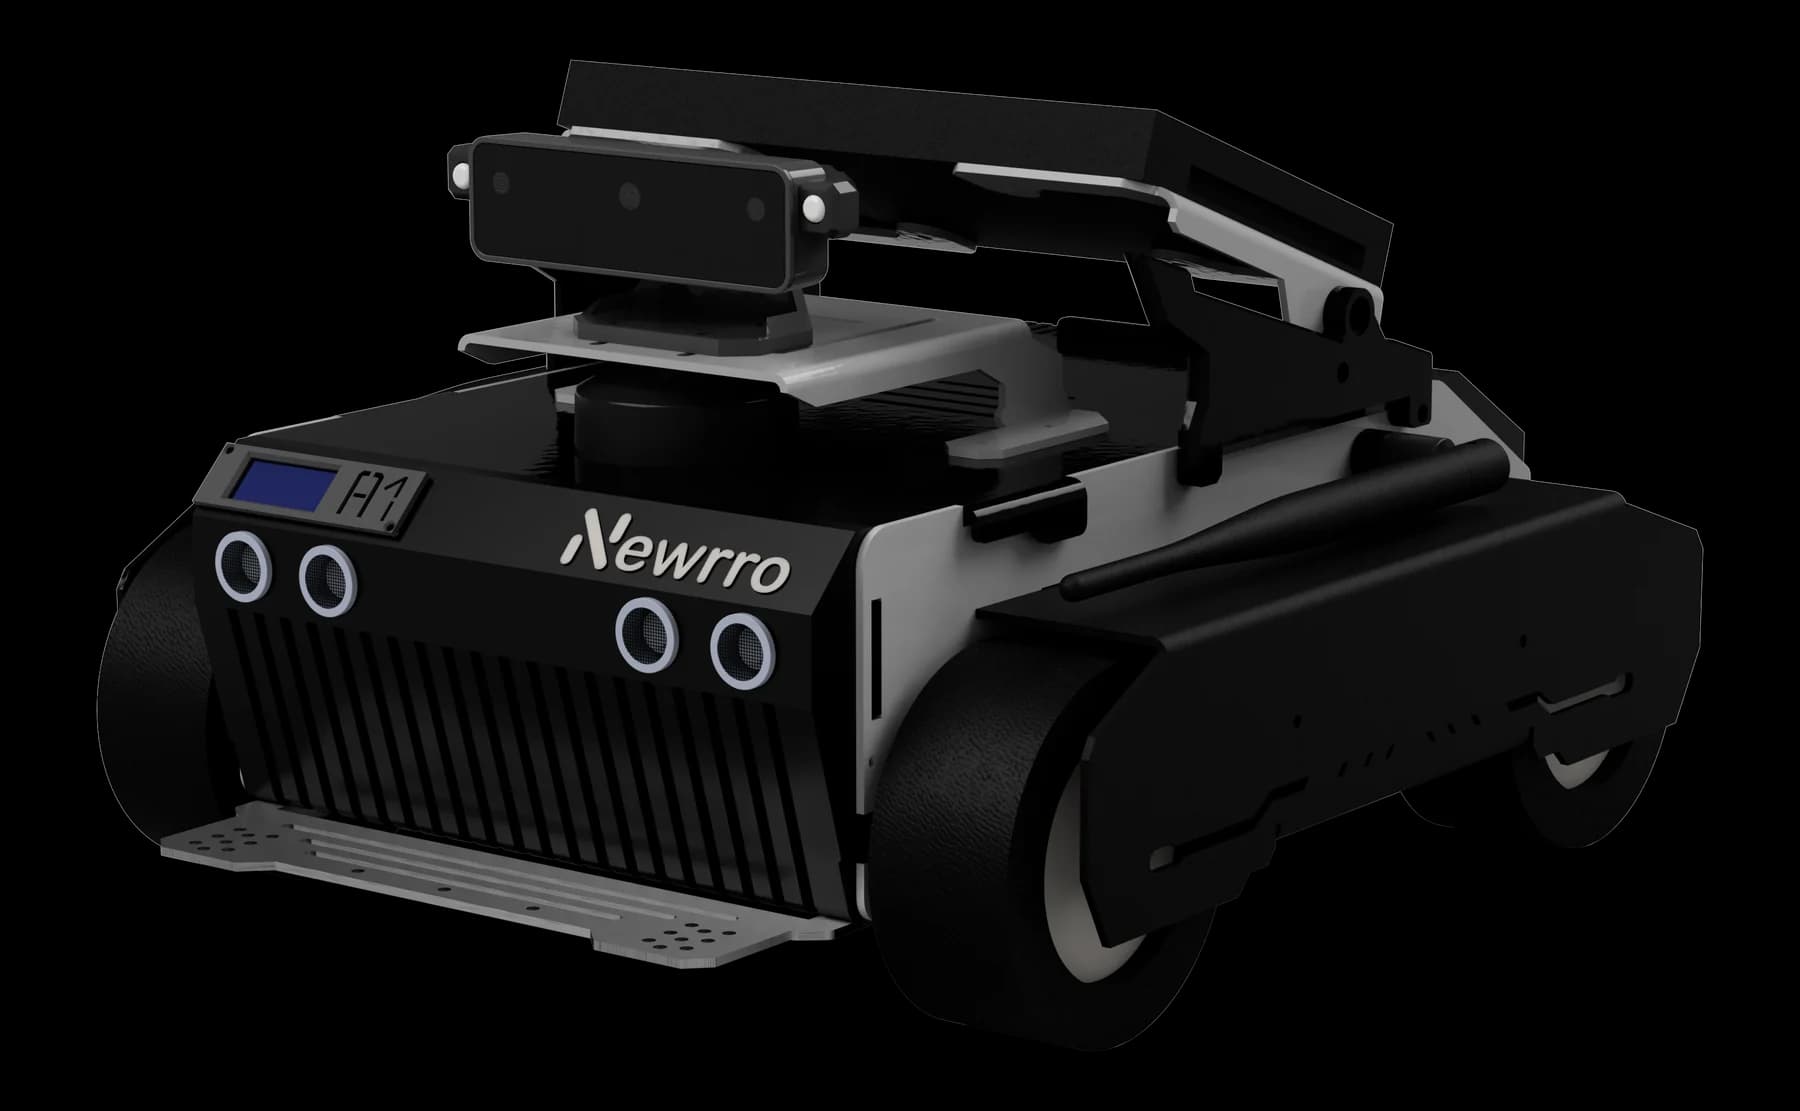
AI-powered ROS-based Autonomous Mobile Robot for research and education
01 · OVERVIEW
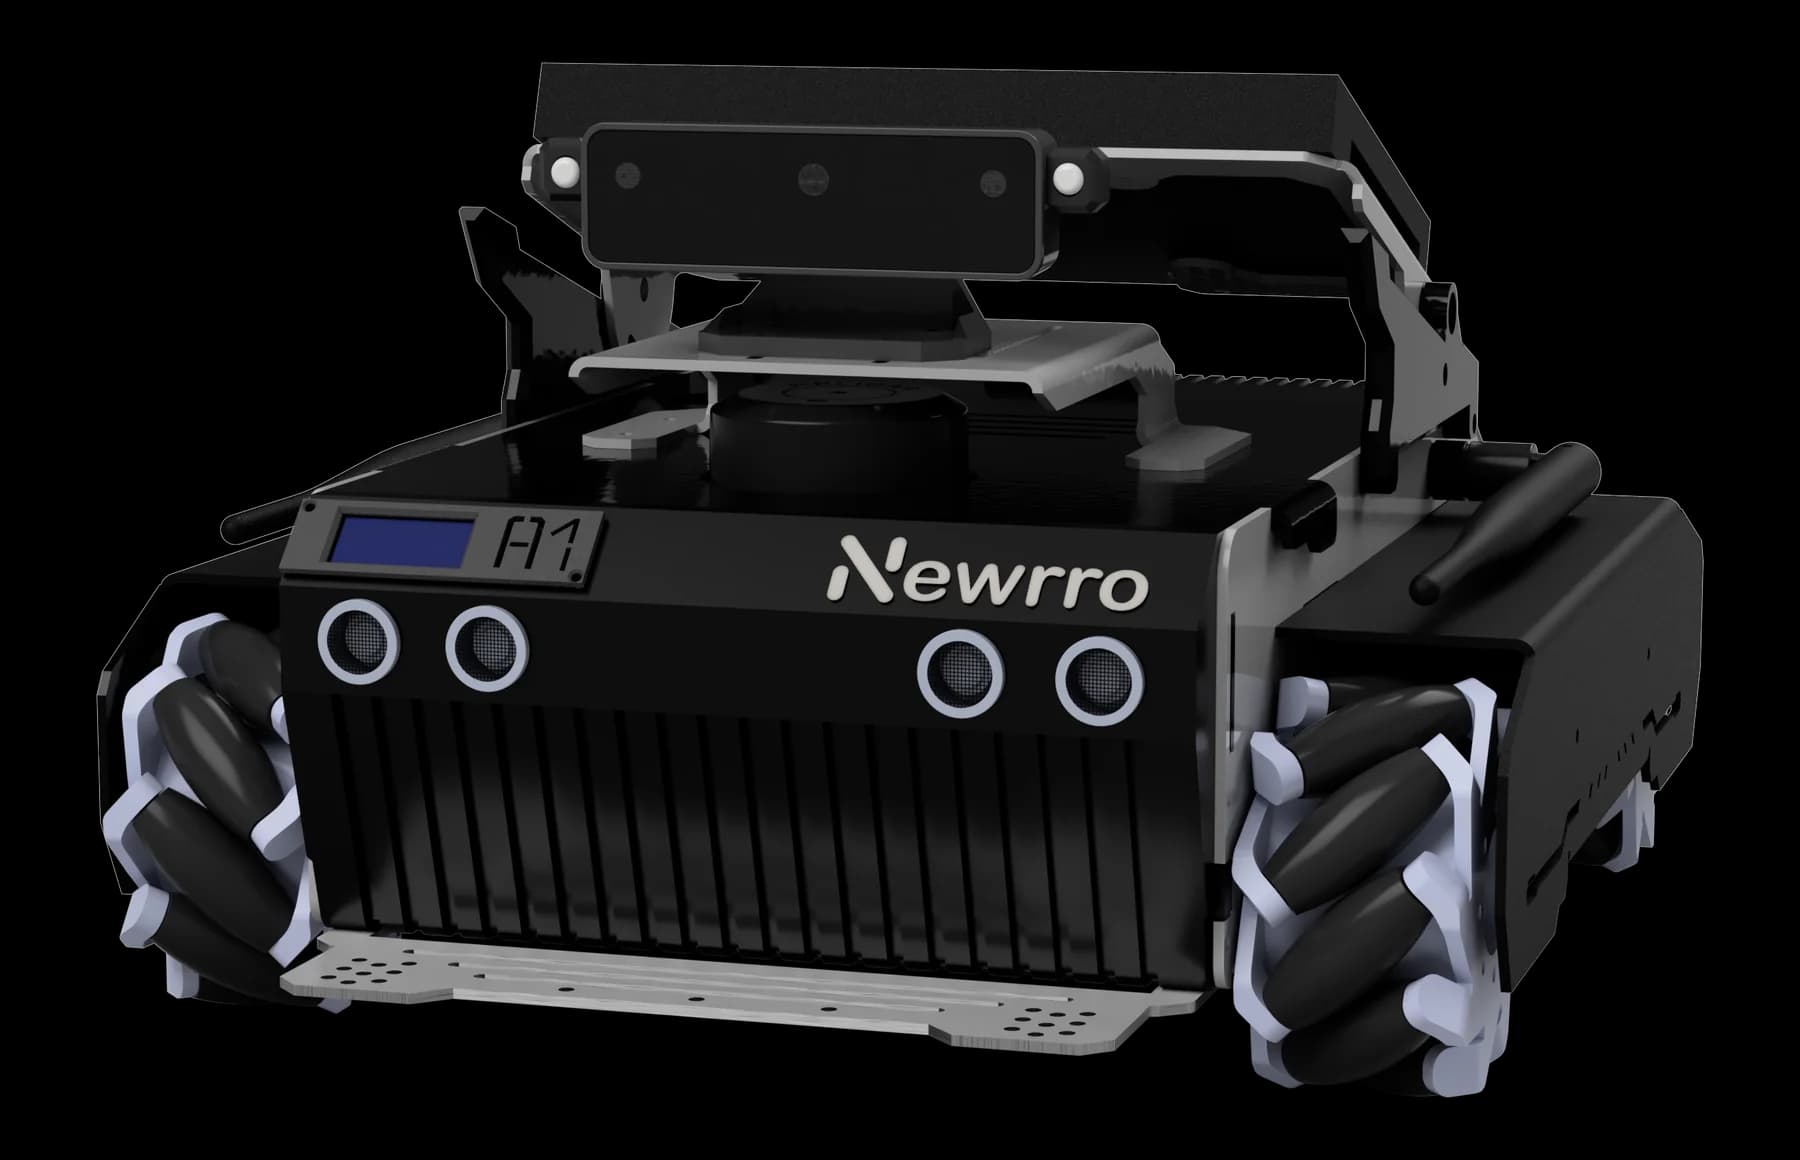
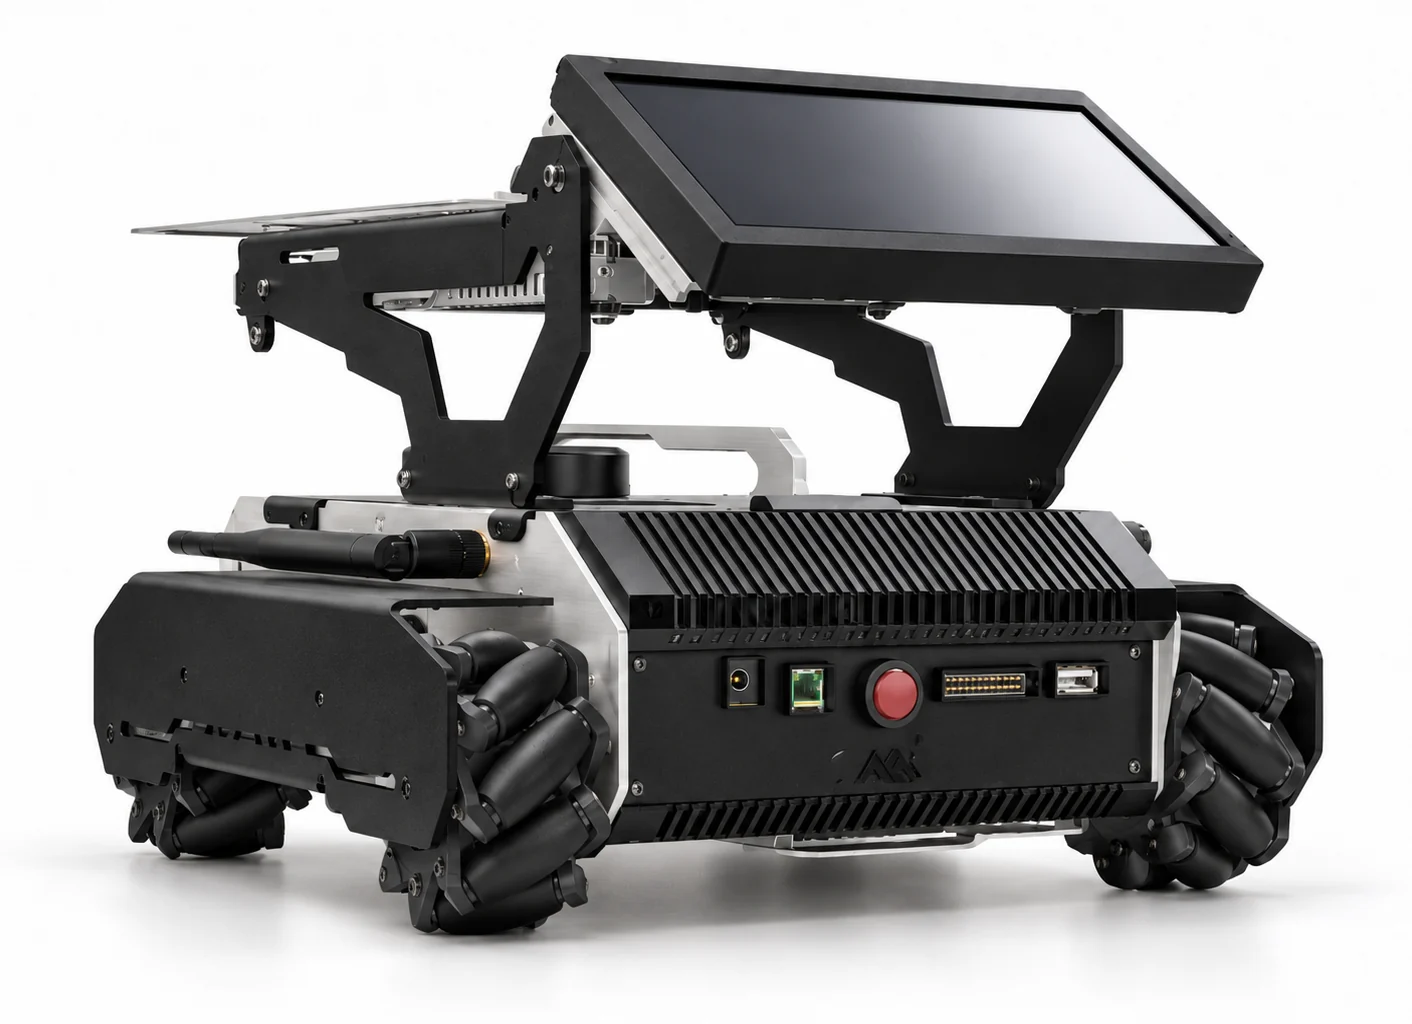
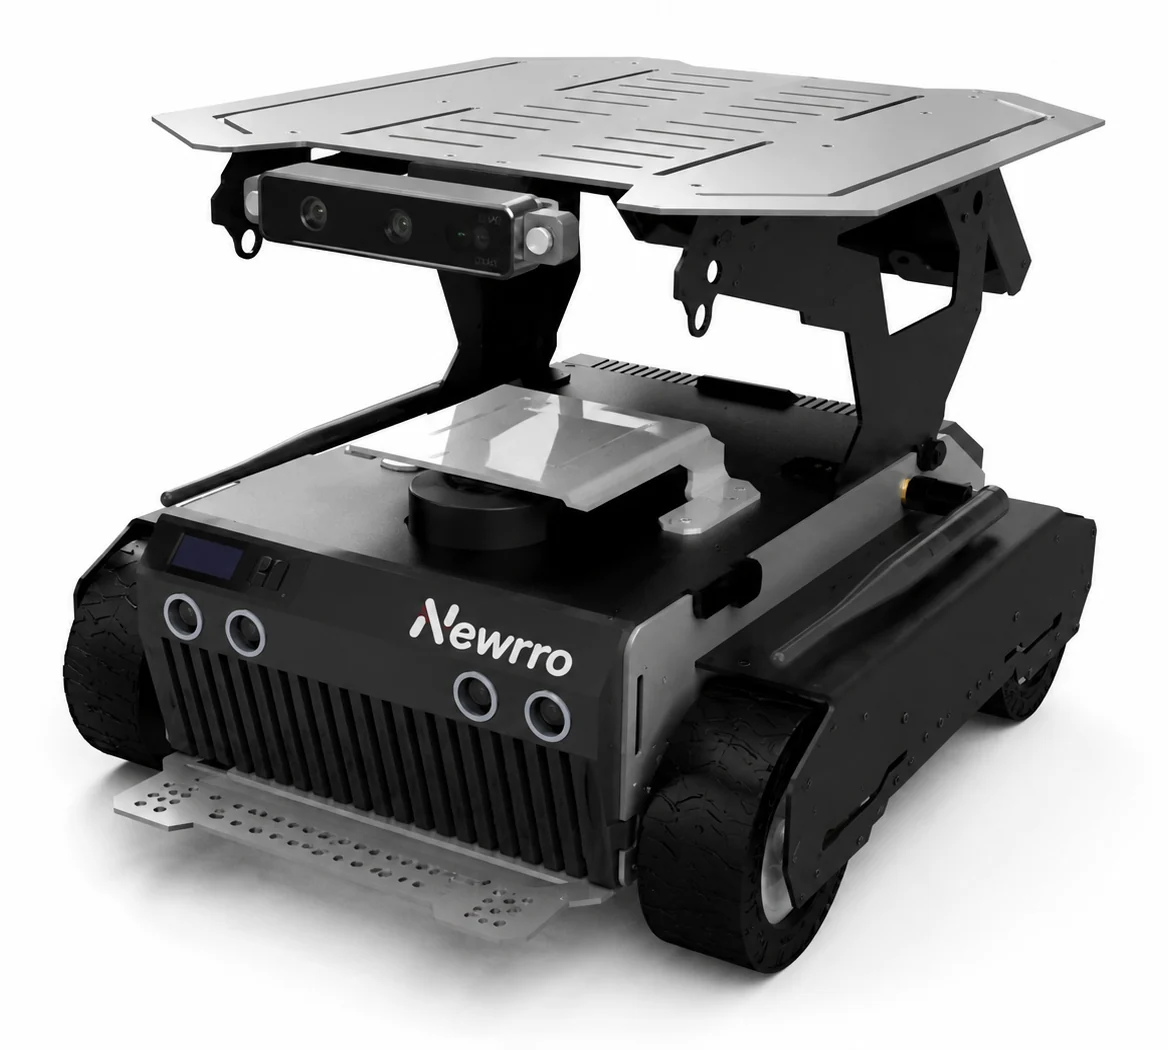
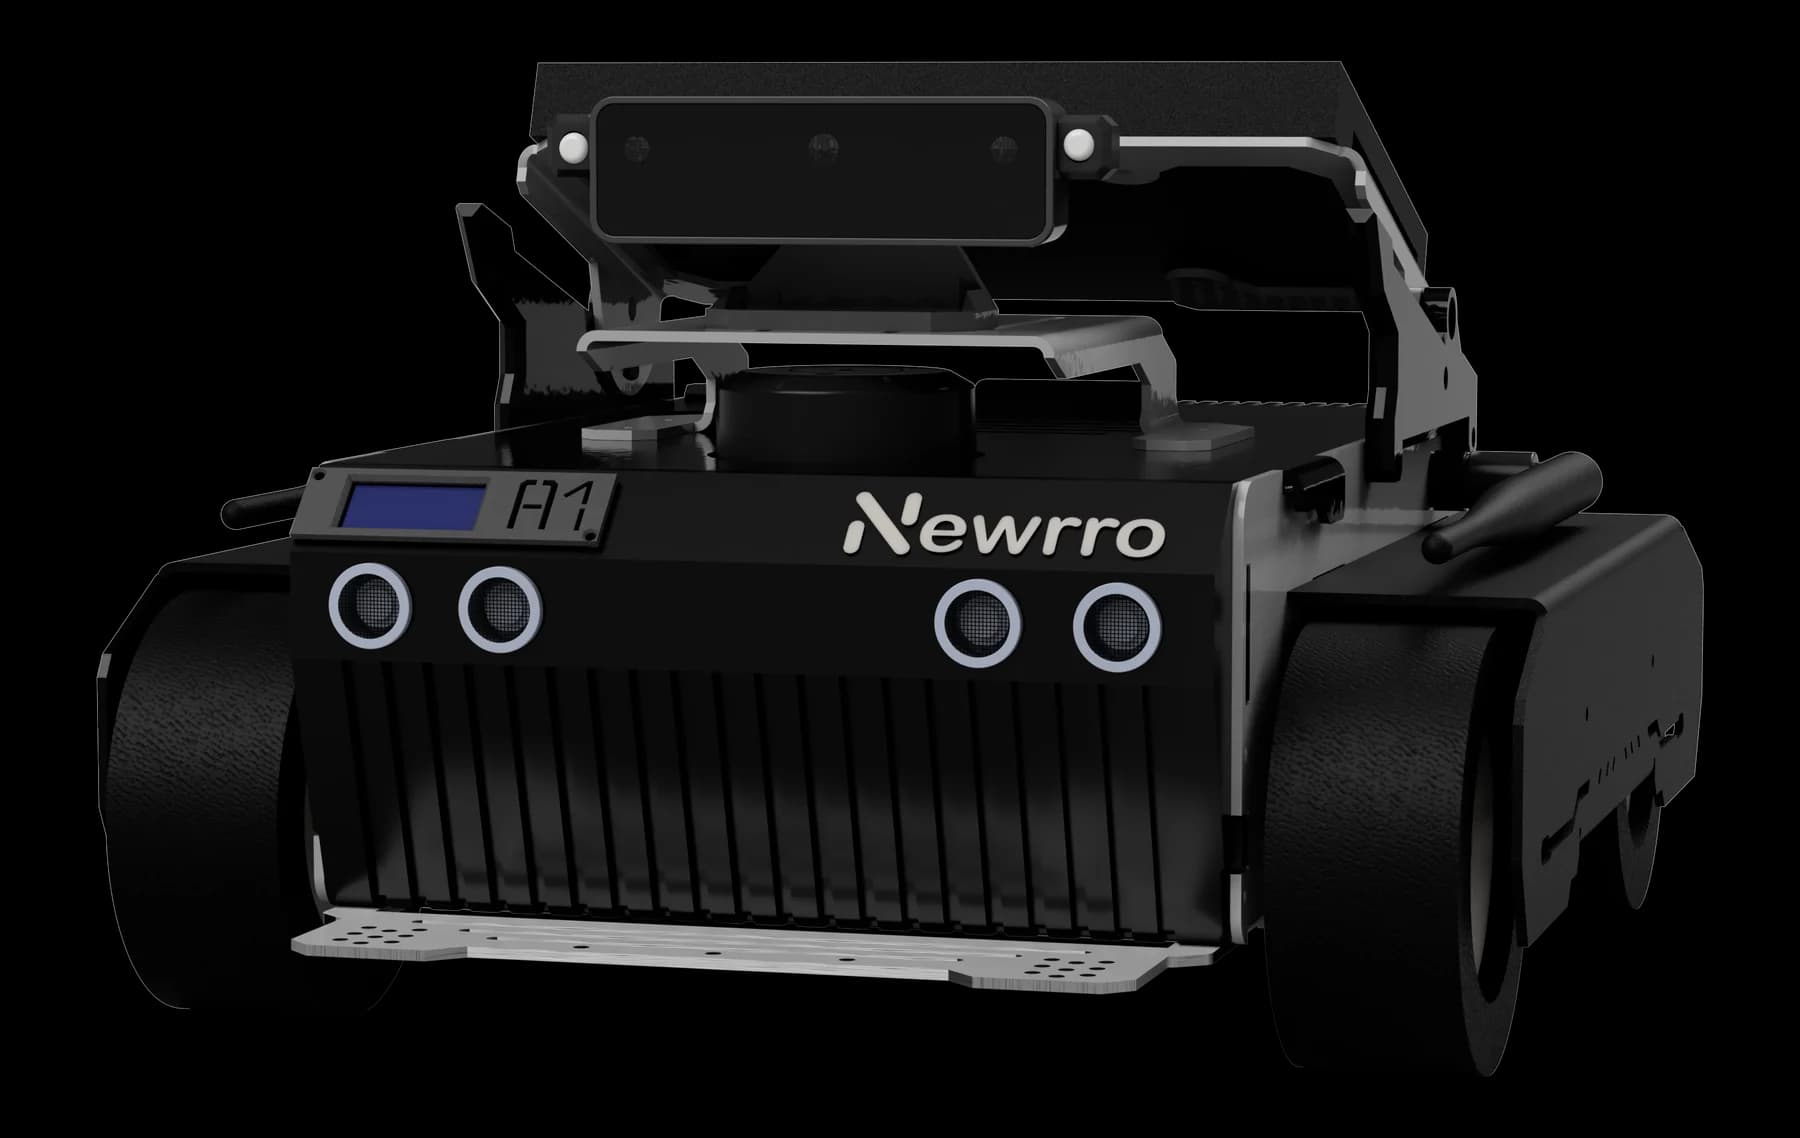
ARJUNA is an Autonomous Mobile Robot (AMR) built for intelligent, reliable navigation using a combination of 360° 2D LiDAR, 3D depth vision and a 9-axis IMU. It leverages SLAM, sensor fusion and autonomous path planning to map its surroundings, localise itself, detect obstacles and navigate dynamically through its environment. Built on a modular ROS architecture, ARJUNA provides a flexible foundation for developing scalable autonomous robotics applications.
Academic
Students program the controller directly, add their own sensors and study SLAM, navigation and perception on hardware that behaves like the industrial systems they'll meet later.
Industry
A ready chassis, drive and sensing stack to build on, so a team can prototype an autonomous product without designing the base robot from scratch.
Deployment
Point-to-point delivery, auto-docking and multi-robot coordination are already implemented, which makes short indoor pilots practical to run.
02 · ANATOMY
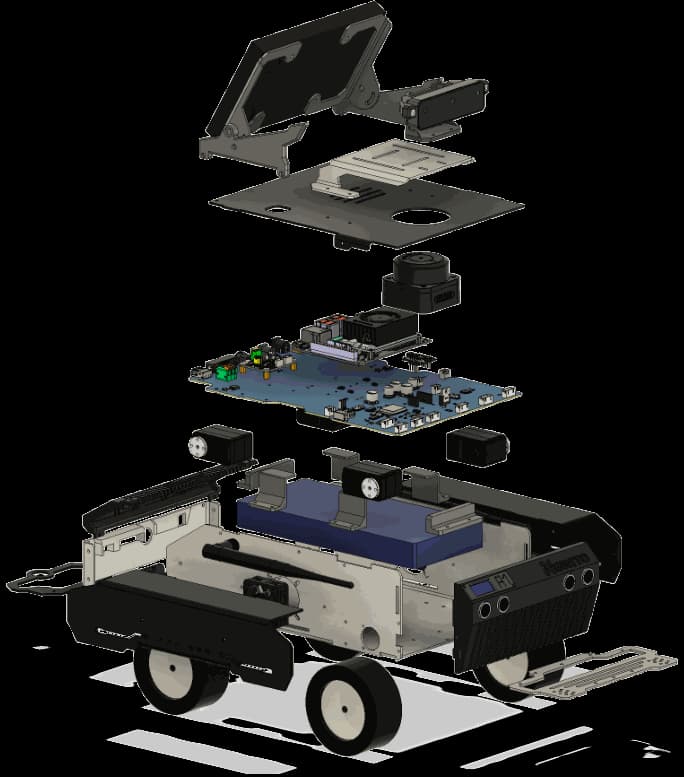
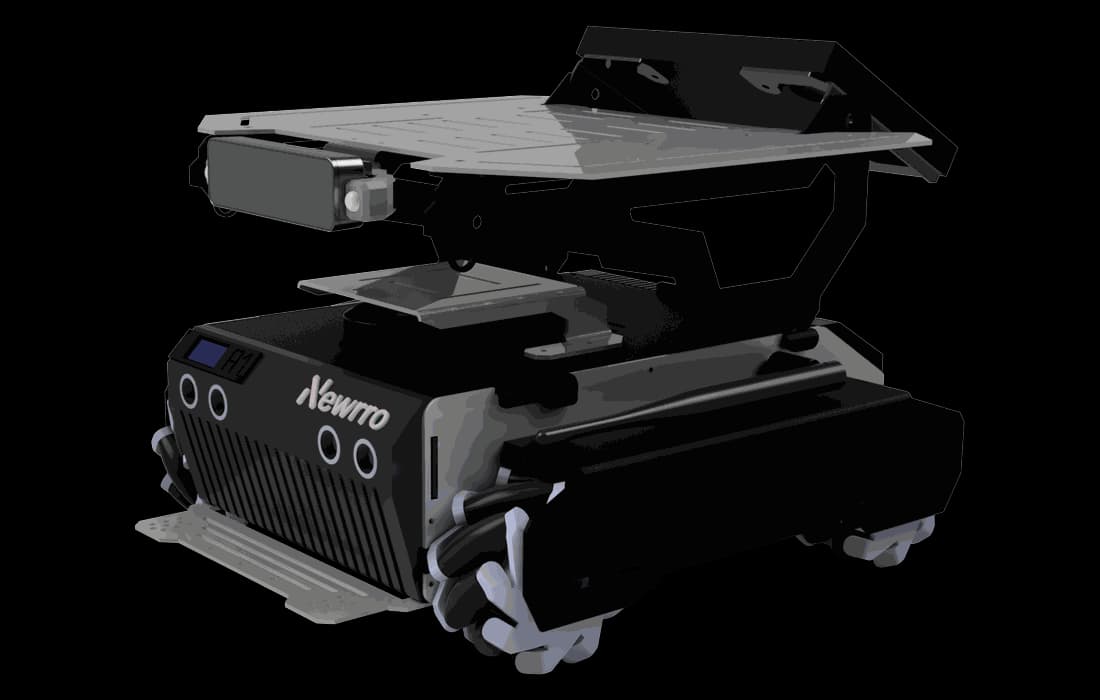
Exploded view · display-mount build
03 · CONFIGURATIONS
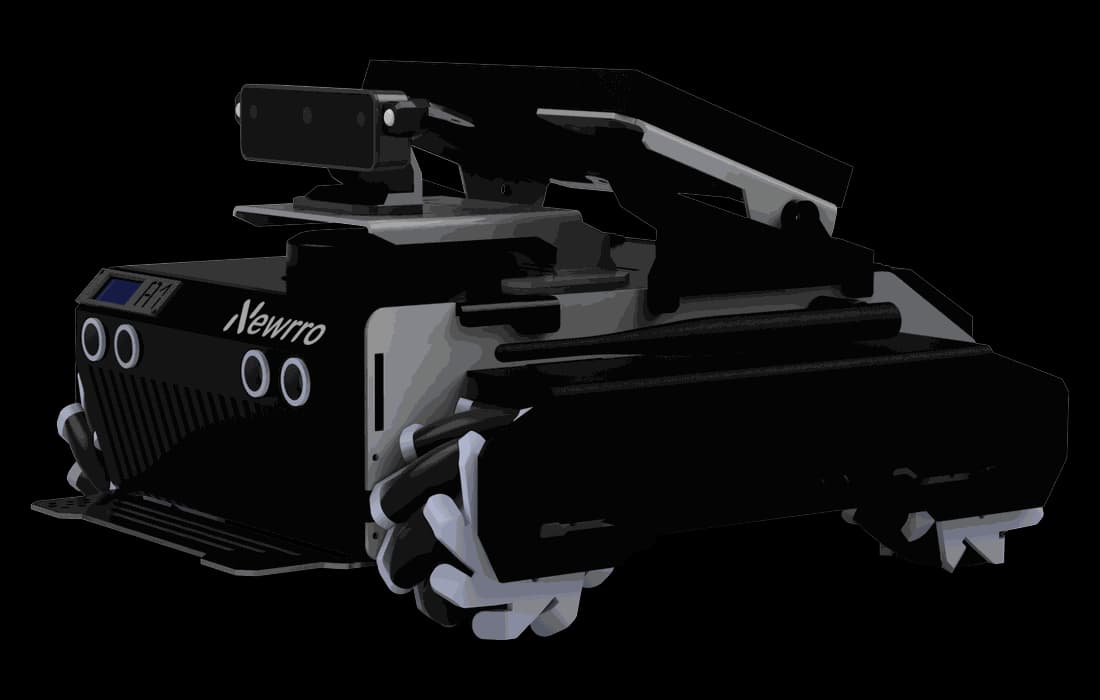
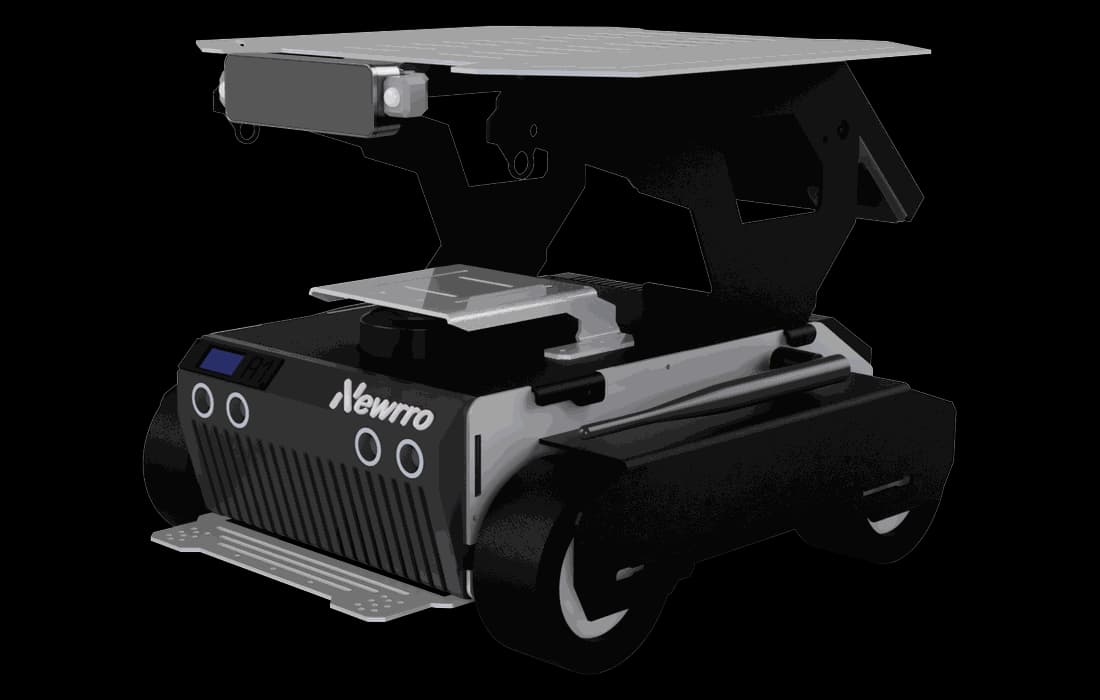
Four choices decide the build. The preview updates as you go, and you can download the configuration as a PDF, email it or share a link to send back to us.
Live preview
Live preview
ARJ-JETS-OAKDP-NO-2DL
Adjustable display only · Jetson Orin Nano Super · OAK-D Pro · 2D LiDAR
Your configuration
ARJUNA, as configured
ARJ-JETS-OAKDP-NO-2DL
Send this configuration to Newrro and we'll quote against its code. Nothing leaves this page until you download, email or share it.
04 · KEY FEATURES
Plans an efficient route to a goal coordinate and re-plans when the map changes.
Detects obstacles that appear mid-run and steers around them in real time.
Builds accurate 2D maps of the space for reliable indoor navigation.
IMU, wheel encoders and LiDAR are fused through an extended Kalman filter for stable, low-drift odometry.
RGB-D input drives live pose estimation, loop closure and scene understanding indoors.
Reads and follows QR markers for identification, docking and delivery routines.
Spoken commands move the robot and it confirms each action back to the operator.
Live video, joystick teleoperation, battery status and mapping from a browser.
USB, I²C, UART and GPIO headers take extra sensors, cameras or compute.
05 · SOFTWARE AND AI
Industry-standard robotics software, with GMapping, Hector, Cartographer and RTAB-Map SLAM.
AMCL and EKF sensor fusion for localisation; Dijkstra, A* and DWA path planning.
Jetson-class compute runs neural networks on board for recognition and behaviour prediction.
Lightweight deep learning models run alongside classical computer vision at low latency.
Depth, IMU and LiDAR combine into a volumetric picture of the surroundings.
Recognises and sorts objects by colour and shape, and follows them on command.
Included with every robot, ready to run on day one and to read, modify and extend.
06 · TECHNICAL SPECIFICATIONS
Indicative figures. Dimensions and performance may vary slightly from the physical unit, and component models are updated from time to time.
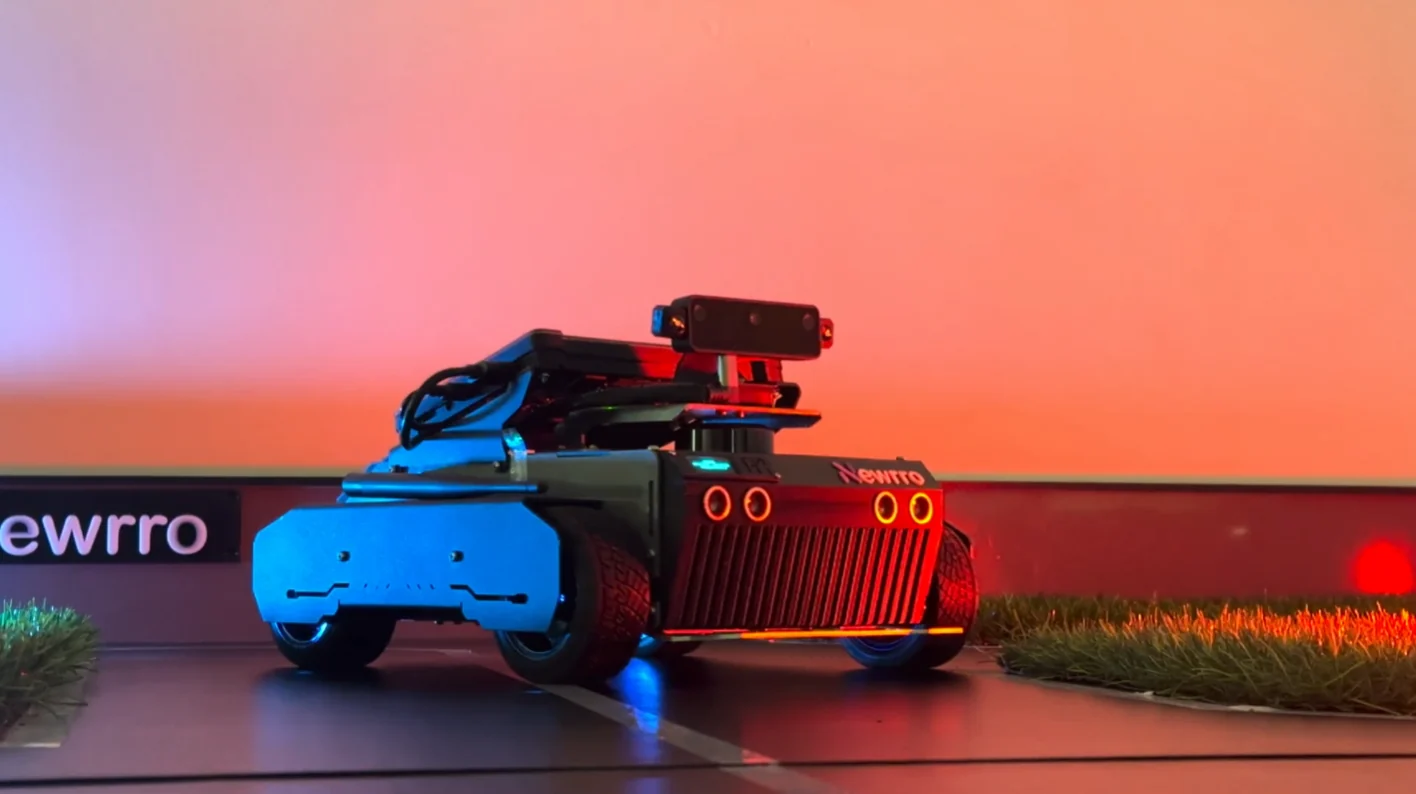
07 · IN THE LAB
08 · RELATED PRODUCTS
AMR
EntryLightweight ROS 2 mobile robot for students, educators and researchers.
Configurations & specsModular AMR
09 · REQUEST A QUOTE
Tell us the quantity you need and the configuration. We respond within 48 working hours.
NEWRRO BOT
Hi, I'm the Newrro bot. What are you looking for?