Products

ABOUT PRAN

P.R.A.N.

Plug-and-play Robotics Architecture by Newrro

A modular architecture that makes robotic components, controllers, compute and software work together.

01 · THE PROBLEM IT SOLVES

Every robotics project starts with the same unanswered questions.

Which controller will drive these motors. Whether this LiDAR will talk to that SBC. What protocol sits between them. How long ROS2 will take to configure. What breaks when a part is swapped.

None of this is the interesting part of robotics. All of it has to be solved before the interesting part begins.

PRAN solves it once, at the architecture level, so it does not have to be solved again on every project.

02 · THE LAYER MODEL

Seven layers. One interoperable system.

  1. 07Cloud & FleetMany robots, managed as one system.In development
  2. 06Navigation (ROS2)Mapping, localisation and path planning.
  3. 05AI & VisionPerception and decision-making at the edge.
  4. 04Autonomy RuntimeRuns the robot's behaviour in real time.
  5. 03Controller & Edge ComputeWhere hardware meets software. The RICK series lives here.
  6. 02Sensor IntegrationLiDAR, cameras, IMUs and encoders, connected and read.
  7. 01Hardware & ActuatorsMotors, drives and the physical robot.

03 · COMPATIBILITY LEVELS

What each level means for you.

[CONFIRM]PRAN-L1 to L5 are defined today; L6 is planned
  1. PRAN-L1Defined

    Electrical compatibility

    it powers and connects

  2. PRAN-L2Defined

    Communication

    devices talk to each other

  3. PRAN-L3Defined

    Software

    the SDK recognises and drives it

  4. PRAN-L4Defined

    ROS2

    works with ROS2 out of the box

  5. PRAN-L5Defined

    Plug-and-play

    connect it and it is configured

  6. PRAN-L6In development

    Industrial

    rated for continuous deployment

PRAN is being integrated across the Newrro product line.

04 · BOUNDARIES

What PRAN is not.

  • Not a single robot.
  • Not a single controller.
  • Not a replacement for ROS2.
  • Not merely a connector, a protocol or a software library.

PRAN is the architecture that lets all of those work together.

05 · TECHNOLOGY STATUS

  • TRL 6–7

    validated through live institutional and deployment pilots

  • ROS2 Humble and Jazzy compatible

  • Multi-sensor, CAN Bus and edge AI integration

Provisional IP filings in preparation for robotics interoperability architecture, controller abstraction systems and adaptive robotics learning infrastructure.

06 · PRAN READY PRODUCTS

Everything we build runs on PRAN.

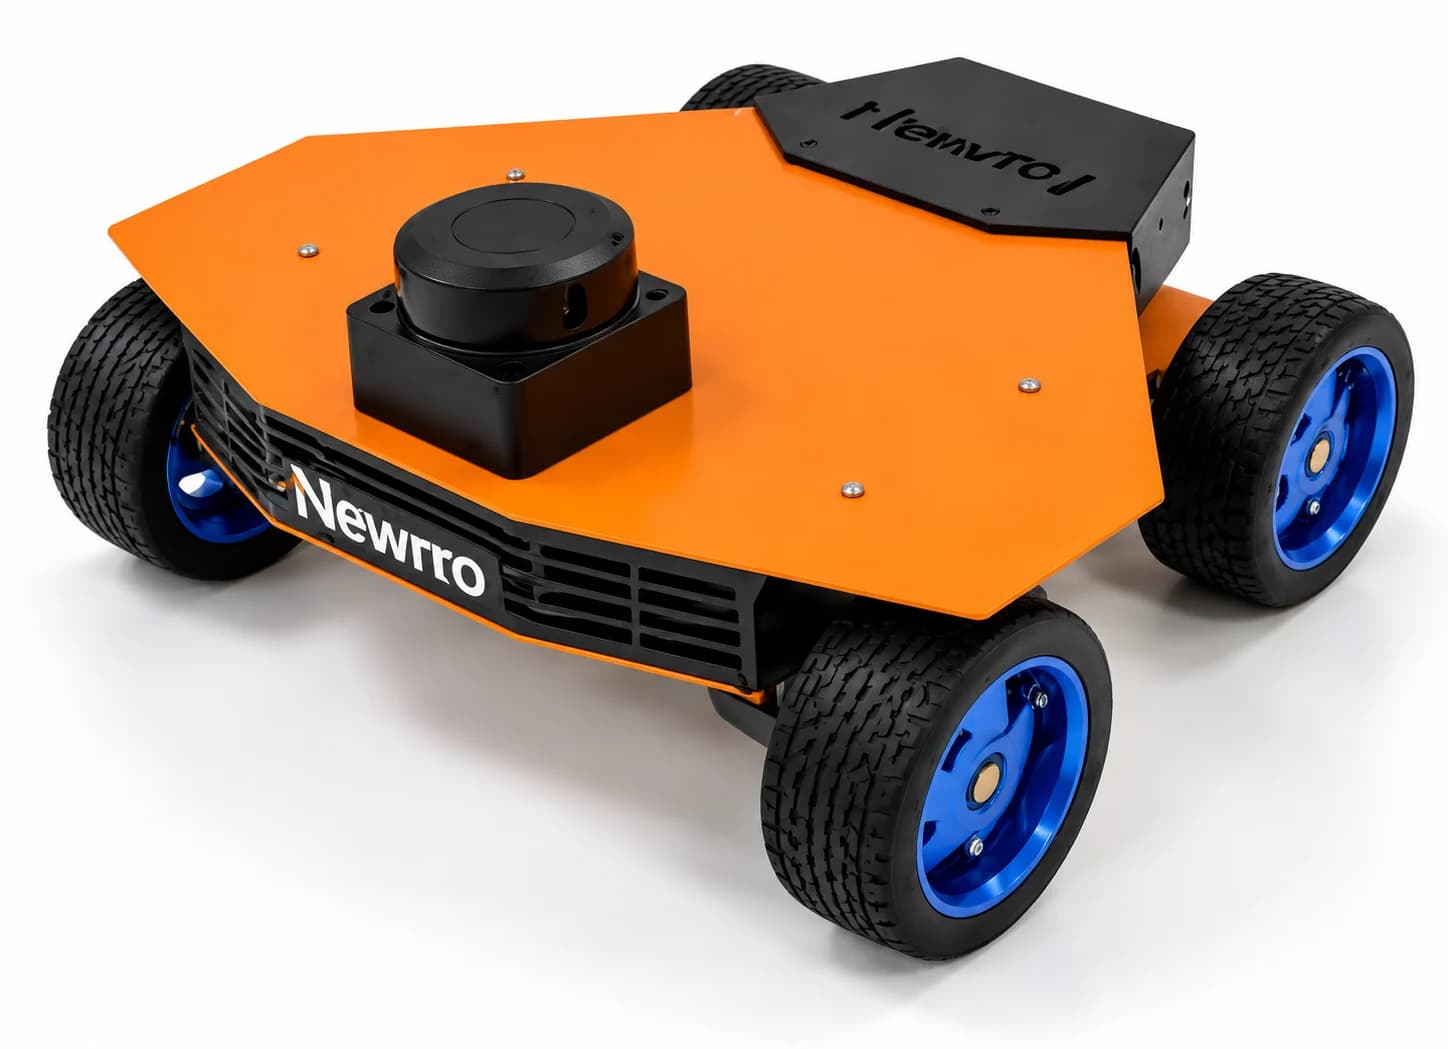
ARJUNA autonomous mobile robot, three-quarter view

AMR

Flagship

ARJUNA

AI-powered ROS-based Autonomous Mobile Robot for research and education

Configurations & specs
BABHRU mobile robot

AMR

Entry

BABHRU

Lightweight ROS 2 mobile robot for students, educators and researchers.

Configurations & specs

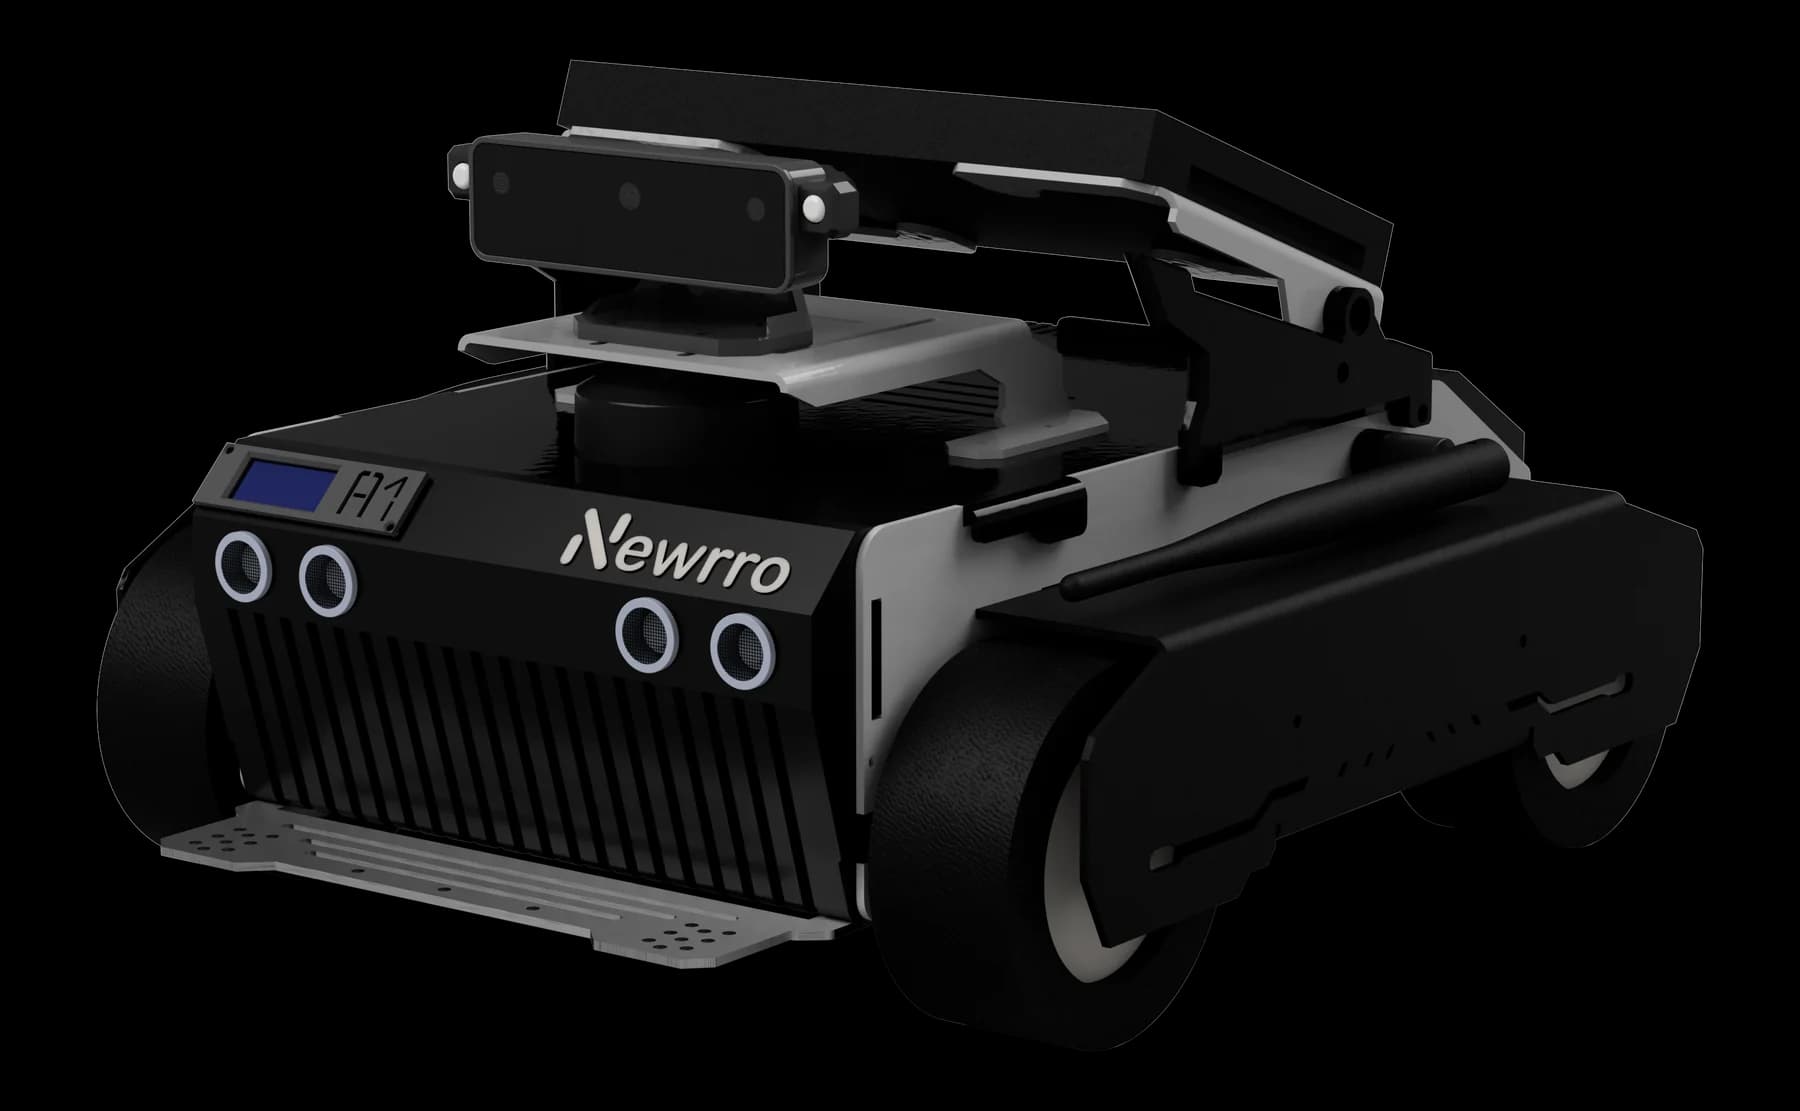
Modular AMR

[SUPPLY]Product photograph

AMR

Reconfigurable

Modular AMR

A reconfigurable AMR built on JetRick.

Configurations & specs
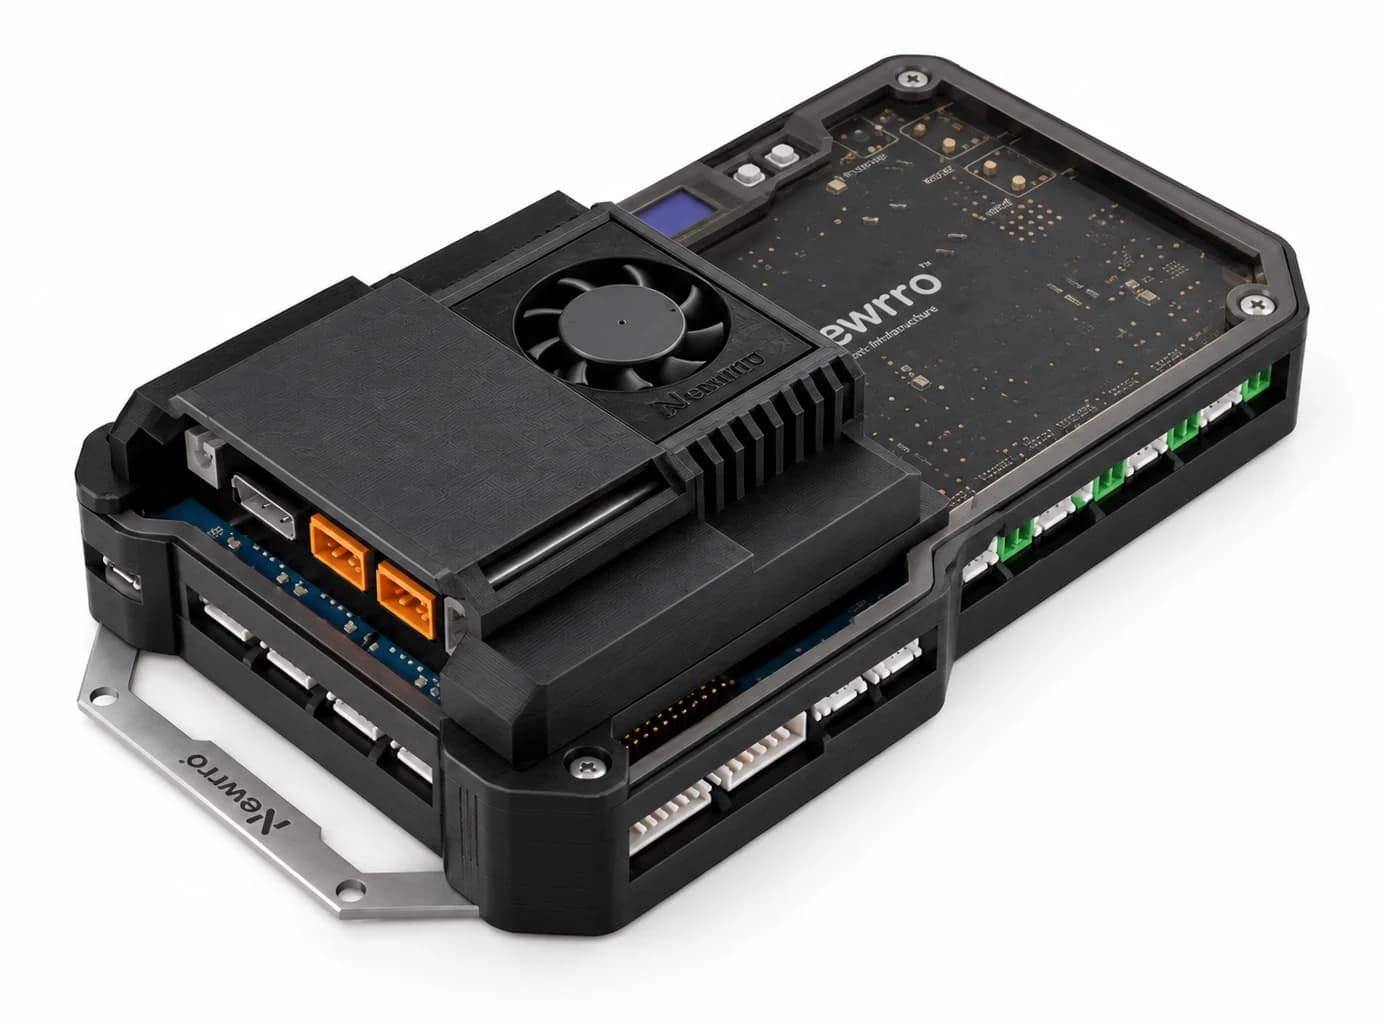
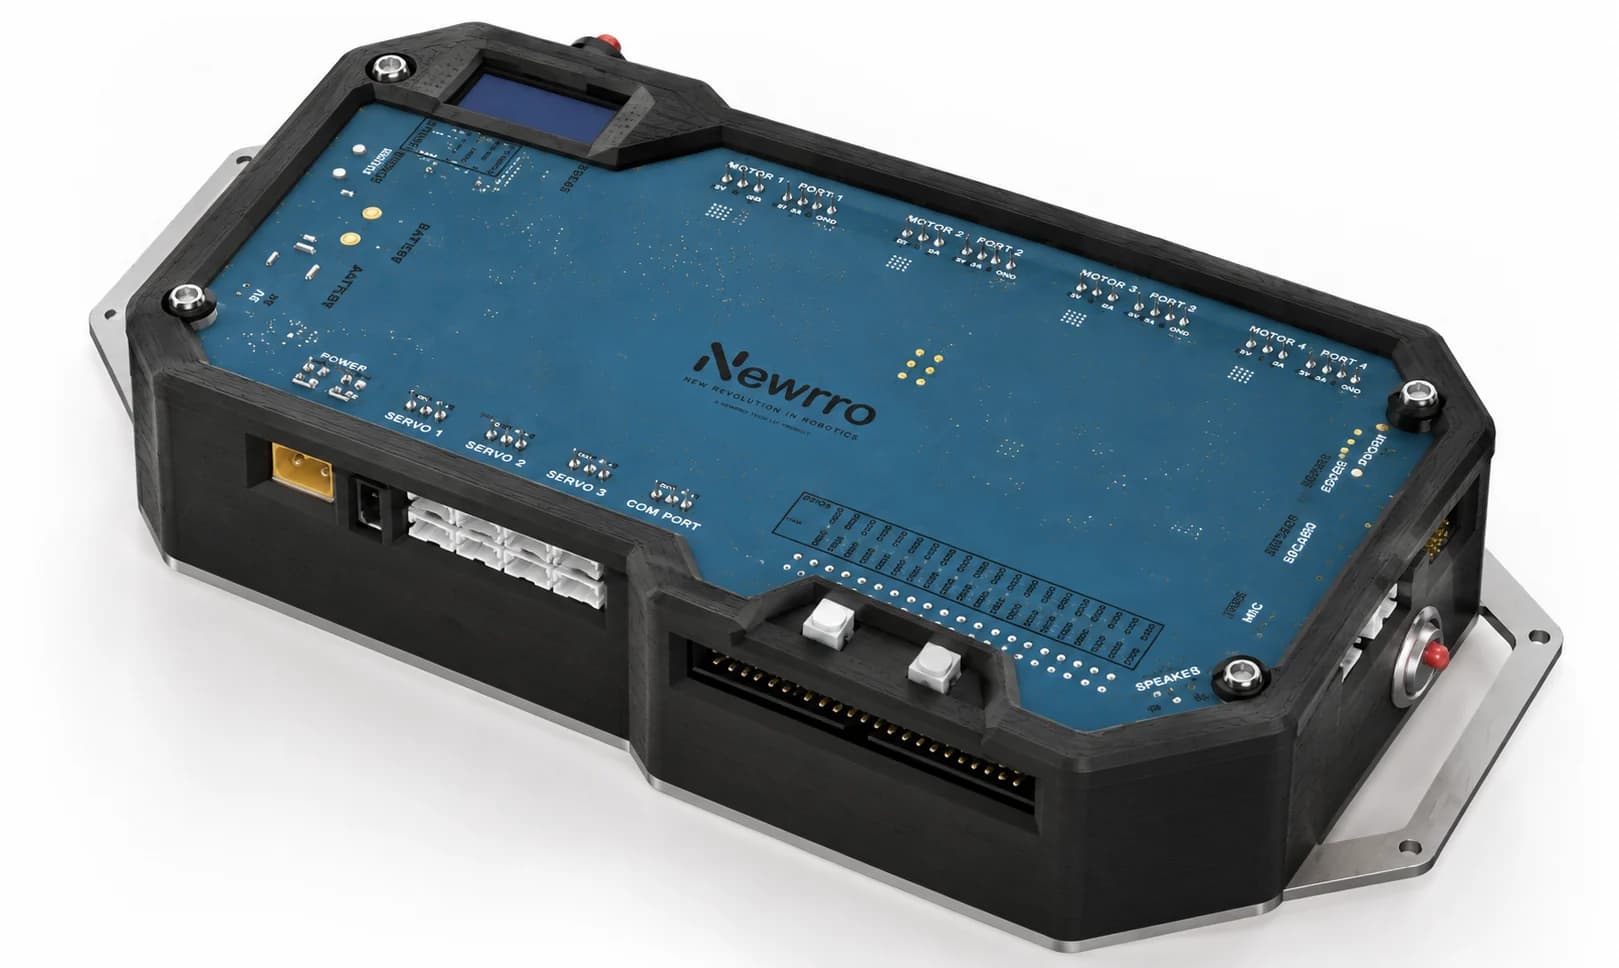
Newrick controller in its enclosure, three-quarter view

RICK

Entry

Newrick

AI & IoT compatible controller

Configurations & specs
JetRick edge AI controller with its Jetson module and heatsink, three-quarter view

RICK

Advanced

JetRick

Edge AI & AMR compatible controller

Configurations & specs
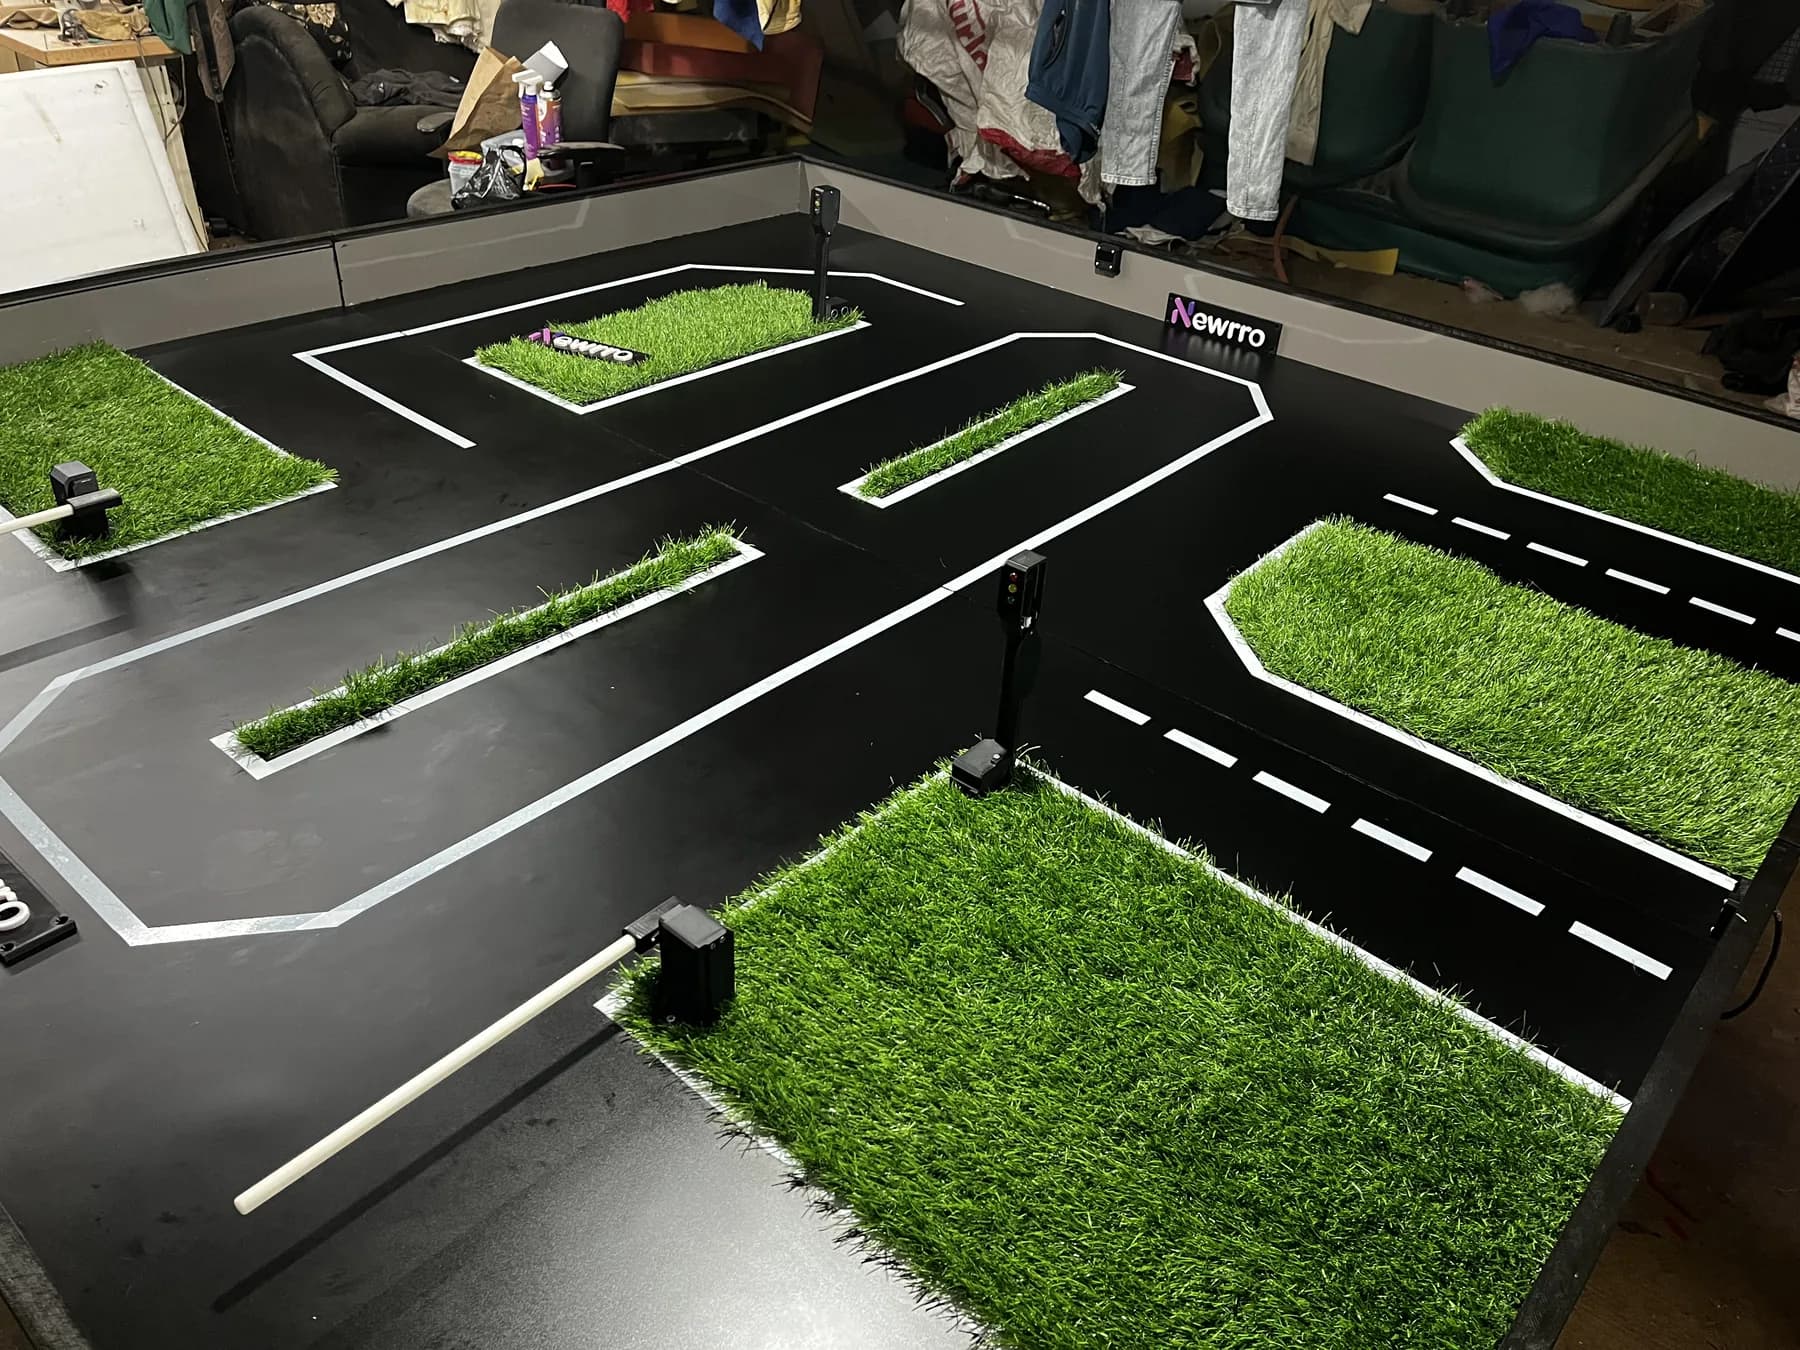
Smart Arena installed: road layout, lane markings and grass zones on the arena base

Arena

Smart Arena

Interactive robotics and simulation platform.

Configurations & specs

Building on PRAN?

Talk to our engineering team about integration, documentation and compatibility.

ABOUT PRAN

0%